Statics and Torque
60 The First Condition for Equilibrium
Learning Objectives
- State the first condition of equilibrium.
- Explain static equilibrium.
- Explain dynamic equilibrium.
An object is in equilibrium when the vector sum of all external forces acting on it is zero. According to Newton's Second Law, this means the object has no acceleration. If the object is at rest, it is in static equilibrium. If it is moving with constant velocity, it is in dynamic equilibrium. Since forces are vector quantities, equilibrium requires that the net force be zero along every coordinate axis. For motion in two dimensions, this means:
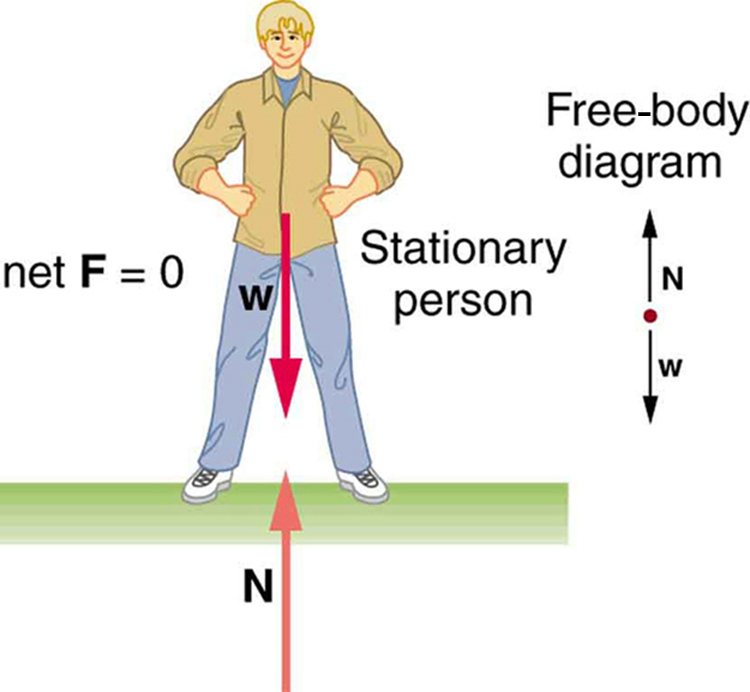
Consider Figure 60.1, which shows a person standing still. The upward normal force from the ground exactly balances the downward gravitational force (weight), so the net force is zero. Because the person remains at rest with no acceleration, they are in static equilibrium.
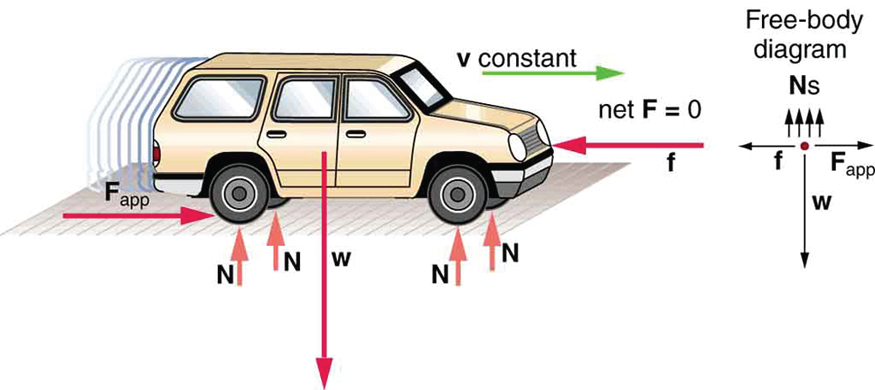
Now consider Figure 60.2. A car moving at constant velocity has balanced horizontal and vertical forces. The horizontal applied force is balanced by air resistance (a form of friction), and the vertical weight is balanced by the normal forces from the road. This is an example of dynamic equilibrium: the object moves but does not accelerate.
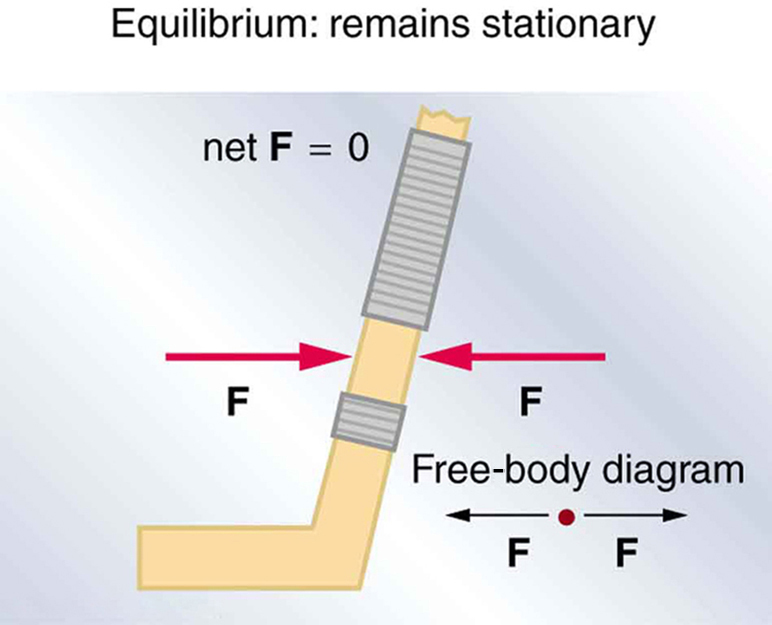
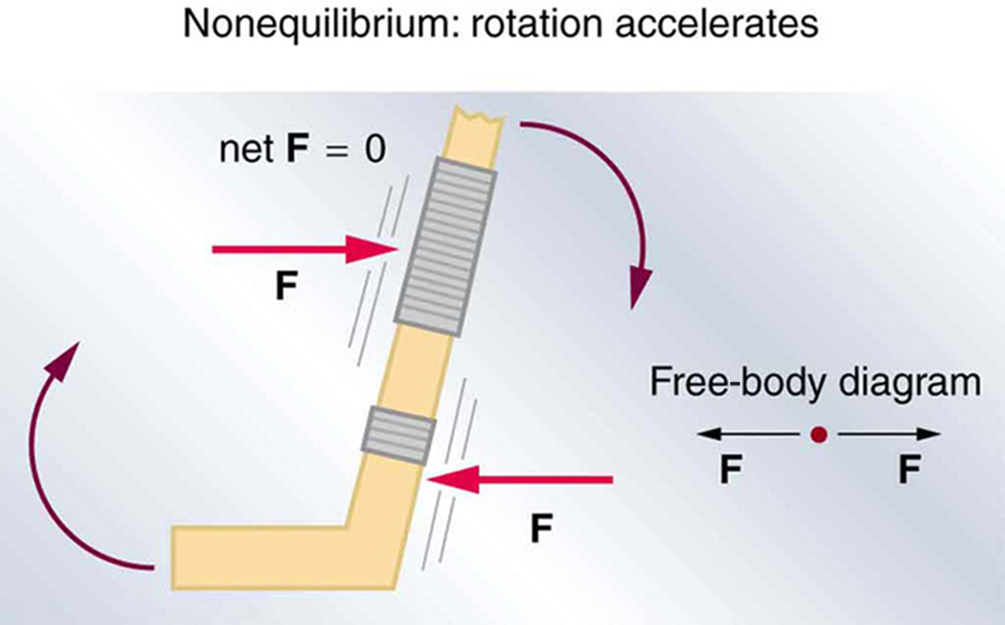
It’s important to note that having zero net force does not necessarily mean there is no motion. It simply means there is no change in motion (no acceleration). However, for a system to be truly in equilibrium, force balance alone is not sufficient. The location where a force is applied also matters, especially when considering rotational effects. Take a look at Figure 60.3 and Figure 60.4. In both cases, two equal and opposite forces act on a hockey stick. In Figure 60.3, the forces act along the same line of action, so the stick stays still. This is true equilibrium. But in Figure 60.4, the same forces act at different locations, producing a torque that causes the stick to rotate. Even though [latex]\text{net}\,\vec{F} = 0[/latex], the system is not in equilibrium because it experiences angular acceleration. We’ll return to this in the next section.
Interactive Exploration: Torque
Torque is the rotational equivalent of force. Just as a force can cause an object to accelerate in a straight line, a torque can cause an object to rotate about an axis. In this simulation, you'll investigate how the magnitude and direction of a force, the distance from the pivot point, and the object's moment of inertia influence rotational motion. Experiment by applying forces at different locations and in different directions. Observe how changing the point of application or the object's mass distribution affects the resulting rotation. As you explore, think about how these principles apply to everyday situations such as opening a door, using a wrench, riding a bicycle, or how muscles rotate bones around joints.
Guided Exploration
As you interact with the simulation, try to answer the following questions:
- Apply the same force at different distances from the center of rotation. How does changing the lever arm affect the resulting torque?
- Apply the force in different directions while keeping its magnitude constant. Which direction produces the greatest rotation? Which produces the least?
- Change the object's mass distribution or moment of inertia. How does this affect the angular acceleration produced by the same torque?
- Apply equal torques in opposite directions. What happens to the object's rotational motion? How does this compare to balanced forces in linear motion?
- Observe the motion when a constant torque is applied. How do the angular velocity and angular acceleration change over time?
- Based on your observations, explain why it is easier to loosen a tight bolt using a long-handled wrench than a short one.
After completing the exploration, compare your observations with the concepts presented in this section. Notice that torque depends on both the magnitude of the applied force and its distance from the axis of rotation. Just as force causes linear acceleration, torque causes angular acceleration, while the object's moment of inertia determines how resistant it is to changes in its rotational motion.
Healthcare Connection
Example 59.1: Calculating Cord Tension in Skeletal Traction
A patient’s leg is in skeletal traction, with a single traction cord running from a distal pin, up over a pulley, and split into two symmetric segments on the other side, each attached to a weight. Each segment makes an angle of 20° with the horizontal traction axis of the leg. If the traction order calls for a net force of 60 N directed straight along the leg’s long axis, find the tension that must exist in each segment of the cord.
Strategy
By symmetry, the vertical components of the two cord segments are equal and opposite, so they cancel automatically and do not need to be included in the first condition for equilibrium. Only the horizontal components need to add up to the required net traction force.
Solution
Each segment contributes a horizontal component of [latex]T\cos \theta[/latex], and there are two symmetric segments, so:
Solving for the tension in each segment:
Discussion
Notice that as the angle [latex]\theta[/latex] increases, [latex]\cos \theta[/latex] decreases, so each segment must carry more tension to deliver the same net traction force—at 60°, for example, each segment would need to carry the full 60 N. This is exactly why traction setups are built with the cord segments as close to parallel with the traction axis as the pulley frame allows: it keeps the required cord tension, and the stress on the pulley hardware, as low as possible for a given clinically prescribed force.
Section Summary
- Statics is the study of forces in equilibrium.
- Two conditions must be satisfied for equilibrium: zero net force and zero net torque.
- The first condition of equilibrium is that the net external force acting on the system is zero:
[latex]\text{net}\,\vec{F} = 0[/latex]
Conceptual Questions
- What can you say about the velocity of a moving body that is in dynamic equilibrium? Draw a sketch of such a body using clearly labeled arrows to represent all external forces on the body.
- Under what conditions can a rotating body be in equilibrium? Give an example.
Glossary
- static equilibrium
- a state of equilibrium in which the net external force and torque acting on a system is zero
- dynamic equilibrium
- a state of equilibrium in which the net external force and torque on a system moving with constant velocity are zero
a state of equilibrium in which the net external force and torque acting on a system is zero
a state of equilibrium in which the net external force and torque on a system moving with constant velocity are zero
